

Control Engineer, Web Developer, Blogger, Photographer
About Me
As a child, I became obsessed with the ridiculous dream of building robots after watching science fiction movies. That harmless gimmick eventually dragged me deep into the labyrinth of Robotics, Automation, and Artificial Intelligence. After sacrificing some of the most valuable years of my life at Yeungnam University to capture the elusive golden deer called a Ph.D., I now find myself pursuing a research career that supposedly aims to save the world through intelligent systems. My so-called academic journey in South Korea has essentially been a peculiar struggle for survival. I came here on a Korean Government Scholarship, only to become trapped in the relentless machinery of Control Engineering, with no obvious escape route left. My master’s research carried the impressive title: “Autonomous Motion Control of Mobile Robot Using Robot Operating System.” In reality, the work involved teaching an omnidirectional robot to navigate through a dynamic industrial environment without crashing into anything, using ROS, LiDAR, and IMU data. That experience pushed me toward even deeper and more painfully complex research in industrial systems. My Ph.D. dissertation was titled “A Study on Machine Learning-Based Control and Fault Detection Methods in Roll-to-Roll Manufacturing Systems.” Instead of relying on conventional mathematical models, I developed an integrated data-driven framework that combined Model-Free Adaptive Control (MFAC) for robust tension regulation with Gaussian Process Regression (GPR) for uncertainty-aware fault detection. By leveraging real-time I/O data, the system was designed to continuously adapt to changing conditions. Experimental results demonstrated tension regulation within ±0.02 N and the ability to detect critical faults in under 100 milliseconds, all without generating false alarms. The long-term goal of my otherwise monotonous academic life is to develop intelligent industrial machinery capable of performing complex tasks while operating safely and seamlessly alongside humans in human-centered environments. For now, I remain determined to keep this academic drama alive indefinitely by researching reinforcement learning-based controllers, AI-driven fault detection techniques, and other suitably grand-sounding topics, all in the name of advancing complex autonomous systems.
Education
Ph.D.
Mechanical Engineering
Yeungnam University
2023 – 2025
M.S.
Mechanical Engineering
Yeungnam University
2021 – 2022
B.S.
Mechanical Engineering
Yeungnam University
2017 – 2020
Awards & Recognition
2018 외국인유학생 한국어말하기 대회
주관상 • 영진전문대학교 • 2018
융합 Capstone Design Project 경진대회
영남대학교 • 2019
Research & Publications
Peer-Reviewed Journals
Integrated Cascade Control and Gaussian Process Regression–Based Fault Detection for Roll-to-Roll Textile Systems
A Neaz, EH Lee, MA Noman, K Cho, K Nam • Machines 13(7), 548 • 2025
Read Paper →Optimizing Precision Material Handling in Industrial Forklifts
FF Amio, N Ahmed, et al. • Electronics 13(9), 1732 • 2024
Read Paper →Optimizing Yarn Tension with Tension–Position Cascade Control Using Kalman Filter
A Neaz, EH Lee, TH Jin, et al. • Sensors 23(12), 5494 • 2023
Read Paper →Integrated Control System for Omnidirectional Mobile Robots in Industrial Logistics
A Neaz, S Lee, K Nam • Sensors 23(6), 3184 • 2023
Read Paper →Conference Proceedings
Robust Tension Control of Modern Winder-unwinder Creel System Using Kalman Filter
Ahmed Neaz et al. • 한국정밀공학회 • 2022
View Proceeding →Automatic Navigation and Motion Control of Mobile Robots Based on ROS and LabVIEW
아메드 니아즈 et al. • IROS 2021
View on Google Scholar →A Robust Model Predictive Control for Autonomous Vehicle Trajectory Tracking
Neaz A., Choi H., Kim J. • ACC 2019
View on Google Scholar →Featured Projects
Remote Management for Industrial Equipment
Integrated IoT platform enabling real-time monitoring and predictive maintenance of manufacturing systems.
4-Wheel Independent Steering Mobility
Advanced control algorithms for omnidirectional mobility platforms with zero-turn radius capability.

Dual Motor EVT for Utility EVs
High-efficiency electric vehicle transmission for 500kg payload utility vehicles.
Autonomous R-MDPS Steering Module
Rack-assist Motor Driven Power Steering system with full autonomous driving capability.

Precision Steering for Agricultural Machinery
GPS-guided autonomous steering control system for tractors and heavy farm vehicles.
ROS-Based Industrial Robotics Suite
Complete software-hardware integration framework for collaborative robots in smart factories.
My Skills
All
Engineering
Coding
Language
Microcontroller
Arduino, Raspberry Pi, STM32, myRIO, Quenser
WordPress
Plugin Creating, Elementor, Front-end, Back-end
3D Modeling & Analisys
Inventor 3D, Ansis, Creator Pro, Simscape Multibody
Basic Programming Language
Programming C, C++, HTML, CSS, PHP
MATLAB
Matlab coding and Simulink for data analysis and control algorithms
Control Engineering
LQR, MPC, Robust Control, Reinforcement Learning Control, Pole Placement
ROS
Robot Operating System for Automation and SLAM
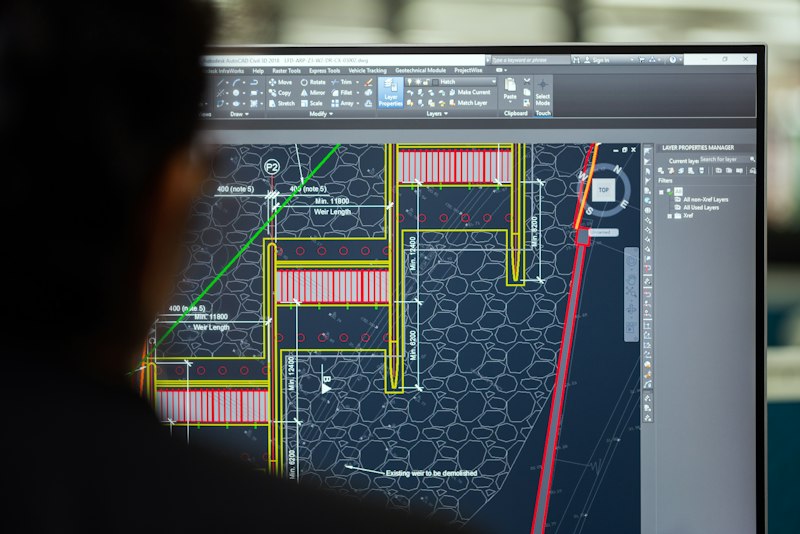
AutoCAD
Engineering Design, Section, Elevation, Machine Design

Python
Data analysis, machine learning, Open CV, Neural network
LabVIEW
NI LabVIEW block code programming, control, and HMI interface making.
Image and Video Making
Adobe illustrator, premiere pro, animate, Microsoft Clipchamp
Academic Writing
SCI journals, Academic report
ROS
Robot Operating System for Automation and SLAM
AutoCAD
Engineering Design, Section, Elevation, Machine Design
MATLAB
Matlab coding and Simulink for data analysis and control algorithms
Microcontroller
Arduino, Raspberry Pi, STM32, myRIO, Quenser
3D Modeling & Analisys
Inventor 3D, Ansis, Creator Pro, Simscape Multibody
Control Engineering
LQR, MPC, Robust Control, Reinforcement Learning Control, Pole Placement
Python
Data analysis, machine learning, Open CV, Neural network
WordPress
Plugin Creating, Elementor, Front-end, Back-end
Basic Programming Language
Programming C, C++, HTML, CSS, PHP
LabVIEW
NI LabVIEW block code programming, control, and HMI interface making.
Bangla
Native
English
General and Academic
Korean
General and Academic
My Job Experiences
Marine Engineer
Served as a officer cadet in Bangladesh Marine.
Web developer
Worked as a freelancer at a spanish IT company as a part time web developer and article writer
Research Assistant
Worked as a research assistant at Mobility Control Lab.
Post Doctor
Worked as a full time researcher at Daegu Gyeongbok Institute of Science and Technology (DGIST)
Assistant Professor
Working as an Assistant Professor at Mechanical Engineering Department, Yeungnam University